Alberta Longhini
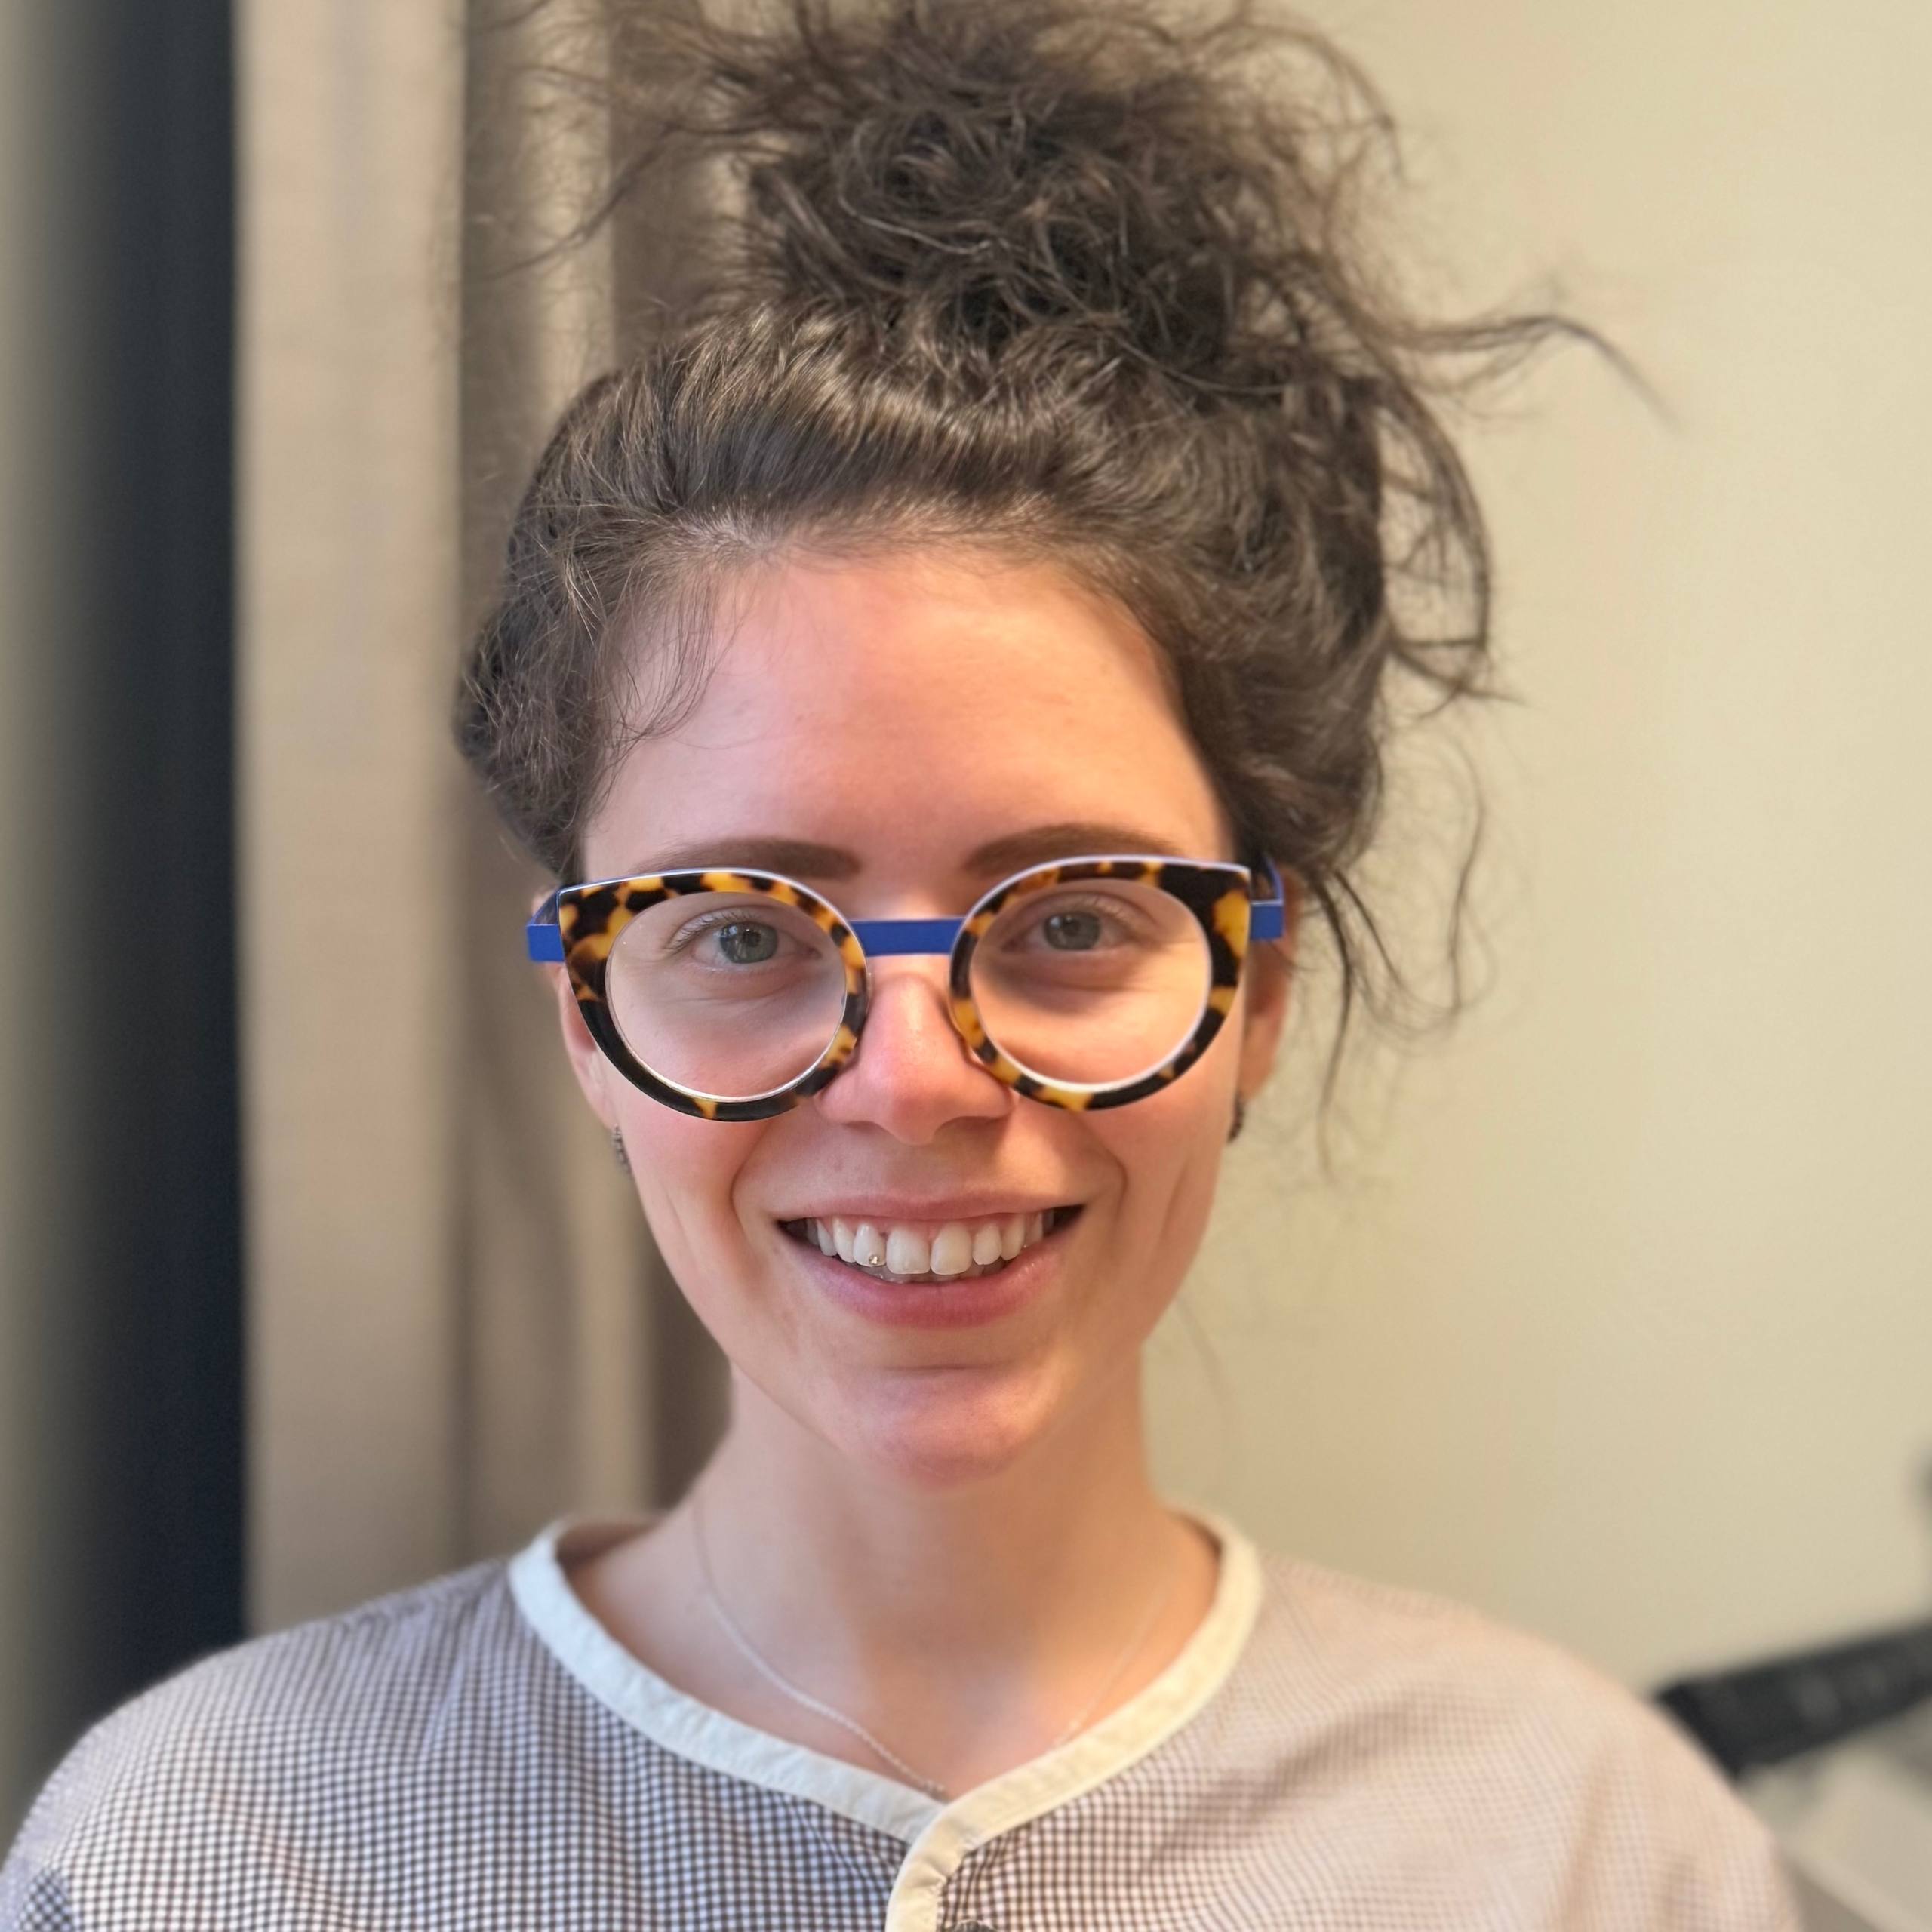
I’m a Postdoctoral Researcher at Stanford University, working with Professor Jeannette Bohg. I obtained my PhD from the KTH Royal Institute of Technology under the supervision of Professor Danica Kragic. Before joining Stanford, I had the pleasure of being part of the RSS Pioneer cohort, and a research intern at Naver Labs Europe, where I worked with the Spatial AI team.
My research focuses on advancing Physical AI by combining structured world models with multimodal perception to help robots adapt their behavior to changing conditions and human requirements. I am particularly interested in how robots can control and adapt existing skills through language and spatial goals, predict whether their outcomes meet task requirements, and learn from failure when they do not. This involves learning representations of the physical properties of real-world objects, embedding physics-based priors into learning systems, and exploring generative and hybrid approaches to improve generalization and sample efficiency. My vision is to develop intelligent robotic systems capable of long-horizon autonomy and robust, adaptive assistance to support humans in real-world scenarios.
Workshop and Challenges
- Workshop: Do Robots Need World Models? — CoRL 2026, Co-Organizer
- Challenge: LeHome Challenge: 1st Simulation-Driven Competition on Deformable Object Manipulation — ICRA 2026, Co-Organizer
- Workshop: RSS Pioneers — RSS 2026, Co-Organizer
- Workshop: Generative Digital Twins for Real2Sim and Sim2Real Transfer in Robotics — ICRA 2026, Co-Organizer
- Workshop: Sixth workshop on Representing and Manipulating Deformable Objects (DOM-R3) — IROS 2026, Co-Organizer
- Workshop: Robot World Models — RSS 2026, Co-Organizer
- Workshop: Human-centric Mobile Manipulation — RSS 2026, Co-Organizer
- Workshop: Learning to Simulate Robot Worlds (LSRW) — CoRL 2025, Co-Organizer
- Workshop: Beyond Rigid Worlds: Representing and Interacting with Non-Rigid Objects (RINO) — CoRL 2025, Co-Organizer
- Workshop: Structured World Models for Robotic Manipulation (SWOMO) — RSS 2025, Co-Organizer
- Workshop: Fifth workshop on Representing and Manipulating Deformable Objects — ICRA 2025, Co-Organizer
- Workshop: Fourth workshop on Representing and Manipulating Deformable Objects — ICRA 2024, Co-Organizer
- PhD Representative - Member of the EECS PhD school council 2023 - 2025
Latest Work
Contact
Email: alberta@stanford.edu
Office: 353 Jane Stanford Way, Room 212.
Address
Interactive Perception and Robot Learning Lab
Computer Science Department
Stanford University
353 Jane Stanford Way
Stanford, CA 94305